
Mercury X1
Mercury X1 is Elephant Robotics’ wheeled humanoid research platform with a 7‑axis arm and onboard NVIDIA Jetson Orin Nano compute.
- Degrees of freedom
- 16
- Height · h
- 40 cm
- Mass · m
- 2.5 kg
- Payload
- 0.5 kg
- Speed · v
- 0.3 m/s
- Form factor
- industrial
- Family
- Commercial General-Purpose Humanoids, Industrial Humanoids
Get to know
the platform.
Mercury X1 is a universal wheeled humanoid robot from Elephant Robotics combining a mobile base with a 7‑axis robotic arm. It’s intended for education and research and supports secondary development via Python and C++ APIs plus common robotics tools (ROS, MoveIt, Gazebo, MuJoCo). The mobile base integrates lidar, ultrasonic sensing, and visual guidance; listed endurance is up to 8 hours.
A few more introductions.

TIAGo
TIAGo by PAL Robotics is a wheeled mobile manipulator for research and education, combining a navigation base with a single arm and sensor suite.
- DoF
- 12
- Height
- 105 cm
- Weight
- 35 kg
- Payload
- 6 kg
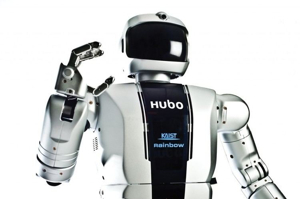
M-Hubo
M-Hubo is a wheeled humanoid research robot from KAIST’s HUBO Lab developed as an autonomous “robotic butler” platform for indoor fetch-and-serve tasks.
- DoF
- 32
- Height
- 120 cm
- Weight
- 45 kg
- Payload
- 5 kg

MOTOMAN HC10DTP
MOTOMAN HC10DTP is a 6-axis collaborative industrial robot arm from Yaskawa with a 10 kg payload for close-proximity operation with people.
- DoF
- 6
- Height
- N/A
- Weight
- 53 kg
- Payload
- 10 kg
Big ideas start with
a conversation.
Thinking about putting Mercury X1 to work? Tell us what you have in mind. We can help connect the hardware, data, and people to take the next step.