✳Research notebook / Technical papers
Curious about the engineering?
Come a little closer. Our research explores the systems behind robot learning, the evidence behind evaluation, and the open questions worth asking next.
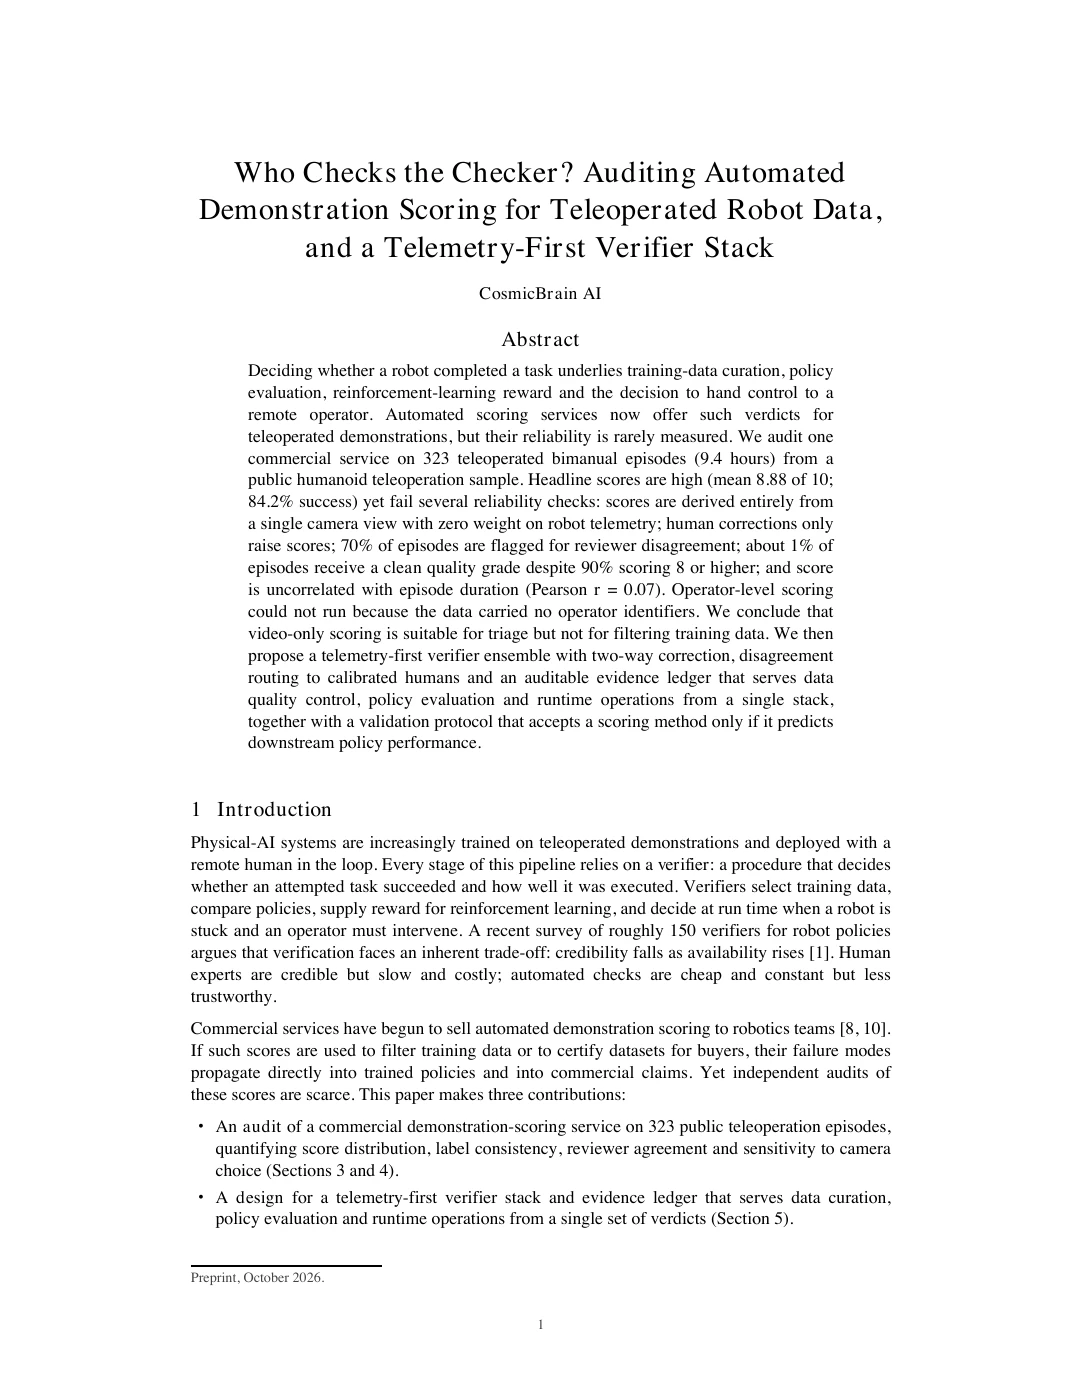
Latest publication / Preprint
Who Checks the Checker?
Auditing Automated Demonstration Scoring for Teleoperated Robot Data, and a Telemetry-First Verifier Stack
An audit of automated scoring across 323 teleoperated robot demonstrations, followed by a proposed telemetry-first verifier stack and a protocol for validating scores against downstream policy performance.
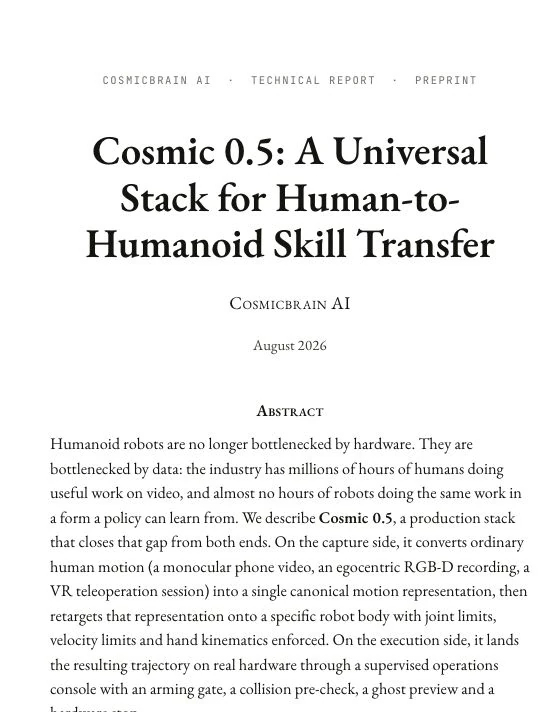
Technical report / Preprint
Cosmic 0.5
A Universal Stack for Human-to-Humanoid Skill Transfer
A technical report on turning human video, egocentric recordings and VR teleoperation into a canonical motion representation, retargeting it across robot bodies, and executing it through a supervised hardware stack.