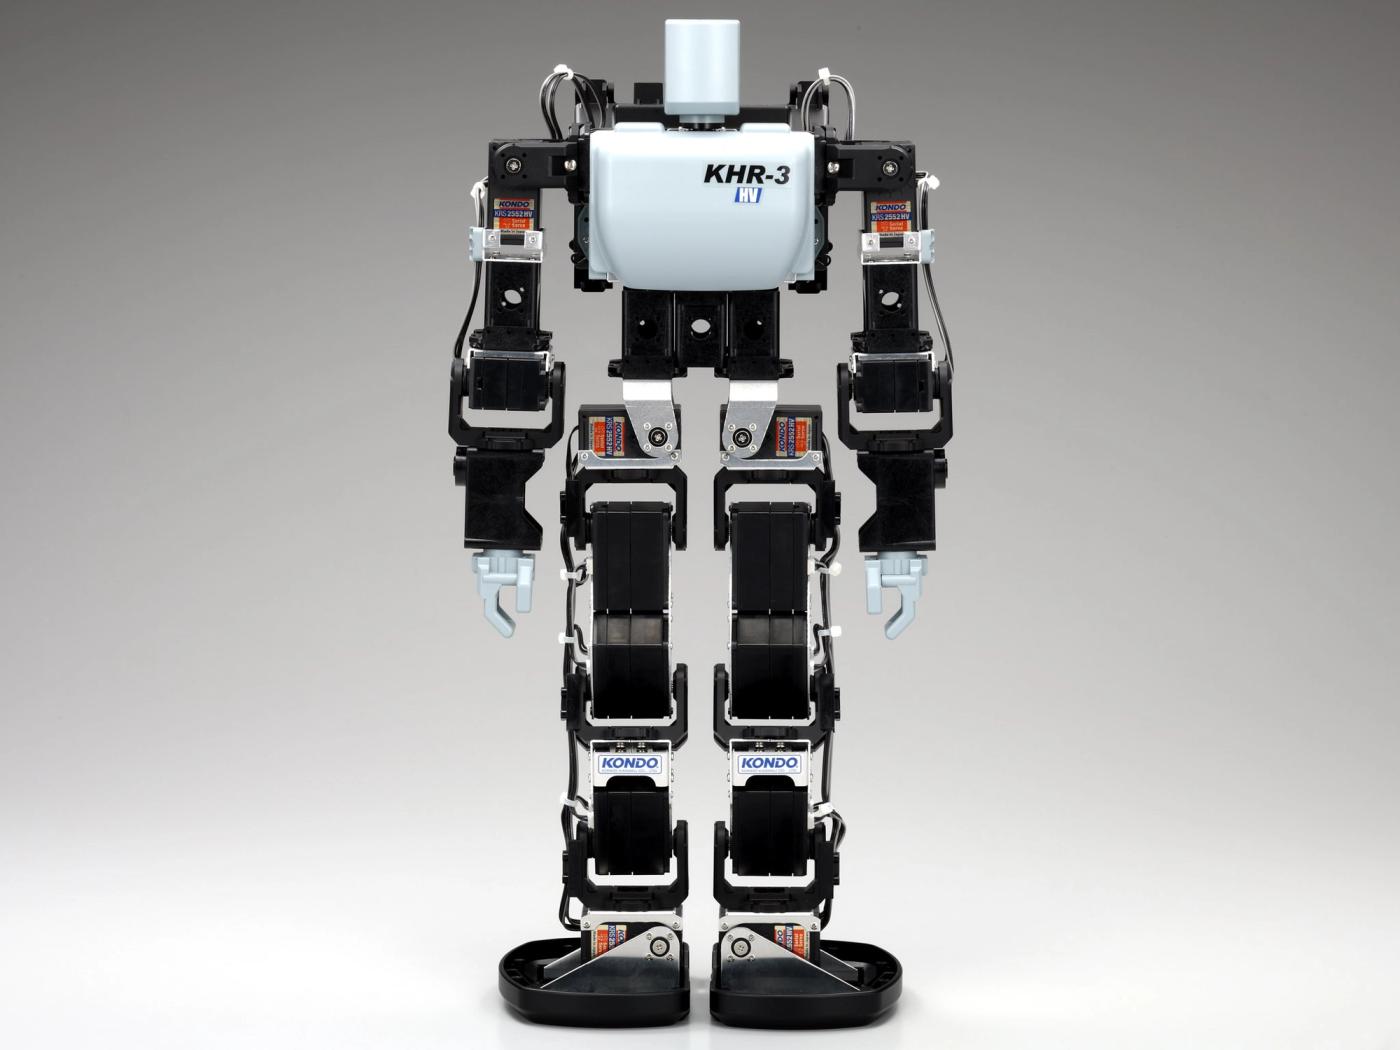
Hubo KHR-3
HUBO KHR-3 is a prototype humanoid robot developed by KAIST’s HUBO Lab for robotics research. It is known for finger independence demonstrations such as rock‑paper‑scissors.
- Degrees of freedom
- 41
- Height · h
- 125 cm
- Mass · m
- 55 kg
- Payload
- Not listed
- Speed · v
- 1.25 m/s
- Form factor
- humanoid
- Family
- Commercial General-Purpose Humanoids
Get to know
the platform.
KHR-3 is a bipedal humanoid research platform from KAIST’s HUBO Lab (South Korea). It is a prototype intended for R&D and education, with articulated hands enabling independent finger motion (demonstrated via rock‑paper‑scissors). Commonly cited platform stats include 41 DOF and a roughly 125 cm, 55 kg body size, supporting full-body humanoid experiments.
A few more introductions.
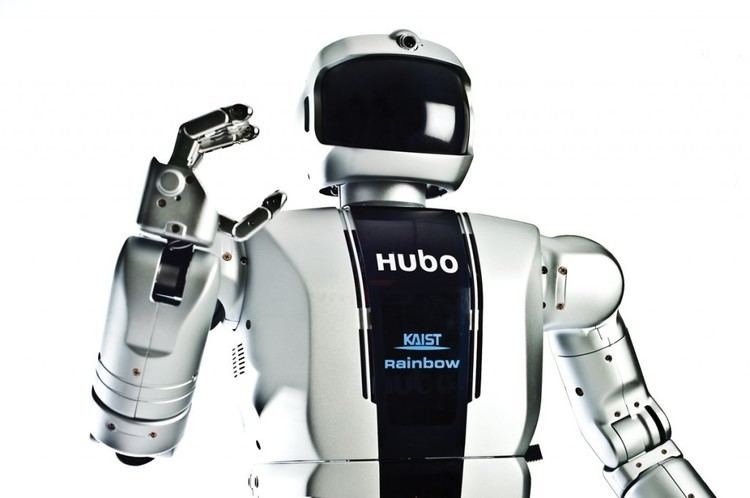
Hubo 2
HUBO 2 is a KAIST Hubo Lab humanoid research robot focused on bipedal locomotion for walking and stair traversal studies.
- DoF
- 40
- Height
- 125 cm
- Weight
- 45 kg
- Payload
- N/A

Hubo (KHR-2 based platform)
HUBO (KHR-2 based) is a full-size biped humanoid research platform developed at KAIST. It is reported at 41 DOF, ~125 cm tall, and ~55 kg.
- DoF
- 41
- Height
- 125 cm
- Weight
- 55 kg
- Payload
- 20 kg

VinRobotics District 1
District 1 is a VinRobotics humanoid robot platform aimed at industrial and service labor applications.
- DoF
- N/A
- Height
- N/A
- Weight
- N/A
- Payload
- N/A
Big ideas start with
a conversation.
Thinking about putting Hubo KHR-3 to work? Tell us what you have in mind. We can help connect the hardware, data, and people to take the next step.